ProLT · Lecture 26 · 27 of 37
Continuous maps preserve the information order
In this lecture
- 0:00 · L26.S01 — A continuous map respects one-way information
- 1:02 · L26.S02 — The converse in finite upper-set spaces
- 1:41 · L26.S03 — A concrete collapsing map
- 2:44 · L26.S04 — Continuity does not control numerical expansion
- 3:25 · L26.S05 — Relate coordinate tests and products
- 4:06 · L26.S06 — Test what preservation means
Complete transcript
Show transcript
An inverse image consists of the source points whose outputs land in a chosen target event. Continuity requires every open target event to have an open inverse image. Our specialization direction says that every open containing v also contains w; for observation spaces, w retains every selected positive true at v.
Continuity preserves the chosen specialization direction. Suppose every source open containing v contains w. To compare their images, start with any target open containing the image of v and pull it backward.
Continuity makes that inverse image source-open. Since it contains v, it contains w. Therefore the original target open contains the image of w. Every target neighborhood of the first image contains the second, proving the comparison.
A map that preserves these comparisons is called monotone. In our finite spaces, every open is upward closed. If a source point lies in the inverse image of a target open, every source point above it maps above its image.
Monotonicity keeps those higher images inside the target open. Its inverse image is therefore upward closed and hence open in the finite source topology. This proves continuity. The finite upper-set description is the assumption making this converse available here.
Give source and target the positive X,Y topology.
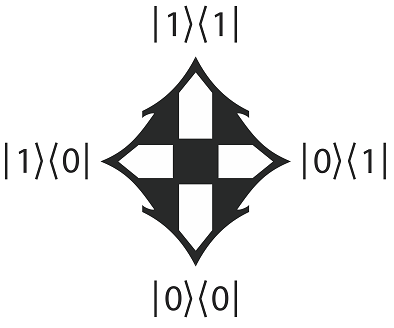
For this map, each side uses the original four X,Y assignments: A is one-zero, B one-one, C zero-one and D zero-zero. The tests are positive X and Y. Read both source and target labels using that same two-bit key. One means true and zero means false.
Send a valuation to two copies of the disjunction of its bits. D maps to D, while A, B and C map to B. Display the map explicitly before attaching any continuity verdict.
D maps to the bottom point and all the nonzero points map to the top point. Every ordered pair remains ordered after applying the map. The map is monotone and therefore continuous, although three distinct points share an image.
Under unit coordinate weights, D and A differ only on X, so their symmetric distance is one. These are the original source points, not their images. Keep the two comparisons on separate labelled rows.
Their images are D and B, which differ on both coordinates. The target distance is two, compared with source distance one. A map is nonexpansive when no pair's distance increases. This continuous map fails that condition, and it also fails injectivity because several inputs share an output.
One can package all selected bit maps into a tuple of Sierpinski-valued coordinates. The product topology is generated by conditions on individual coordinates. Pulling those conditions back gives exactly the selected truth-region generators.
The observation topology is the smallest source topology making every selected bit coordinate continuous. This is the initial-topology description. It recovers the same space; it does not recover an arbitrary list of weights or a unique observation presentation.
Does continuity guarantee that no pair's symmetric distance increases? Use the displayed map and the pair D, A. State separately what continuity does preserve and what this example refutes.
The map preserves every positive-information comparison, but it changes this distance from one to two. Continuity preserves the qualitative order in these finite spaces; the quantitative distances contain additional presentation and weight data.
We now have two compatible tests: pull back target opens, or preserve specialization comparisons in these finite upper-set spaces. Neither test asserts preservation of identities, distances or all distinctions between source points.